The Unitree G1 is a state-of-the-art humanoid robot that impresses with its remarkable mobility and advanced technology. With an exceptionally wide joint range of motion and – depending on the version – up to 43 powered degrees of freedom, it significantly surpasses the mobility of an average human.
Through the use of imitation learning and reinforcement learning, the robot continuously evolves its capabilities and steadily improves its performance in the field of artificial intelligence.
A standout feature of the G1 is its ability to autonomously rise from a lying position to a standing position. Without any external assistance, it gets back up and is immediately ready for operation.
Note: This function is not available when the robot is equipped with Hands.
The G1 can be intuitively and precisely controlled using the VirDyn Full Suit. By capturing human motion in real time, the suit directly transfers the user’s kinematics to the robot. This enables complex motion sequences, grasping tasks, and interactions to be performed naturally and without extensive programming.
This form of teleoperation enables rapid deployment and flexible use cases, such as research, AI model training, or demanding manipulation tasks. At the same time, the high-resolution, low-latency data transmission ensures stable and synchronized motion between human and machine.
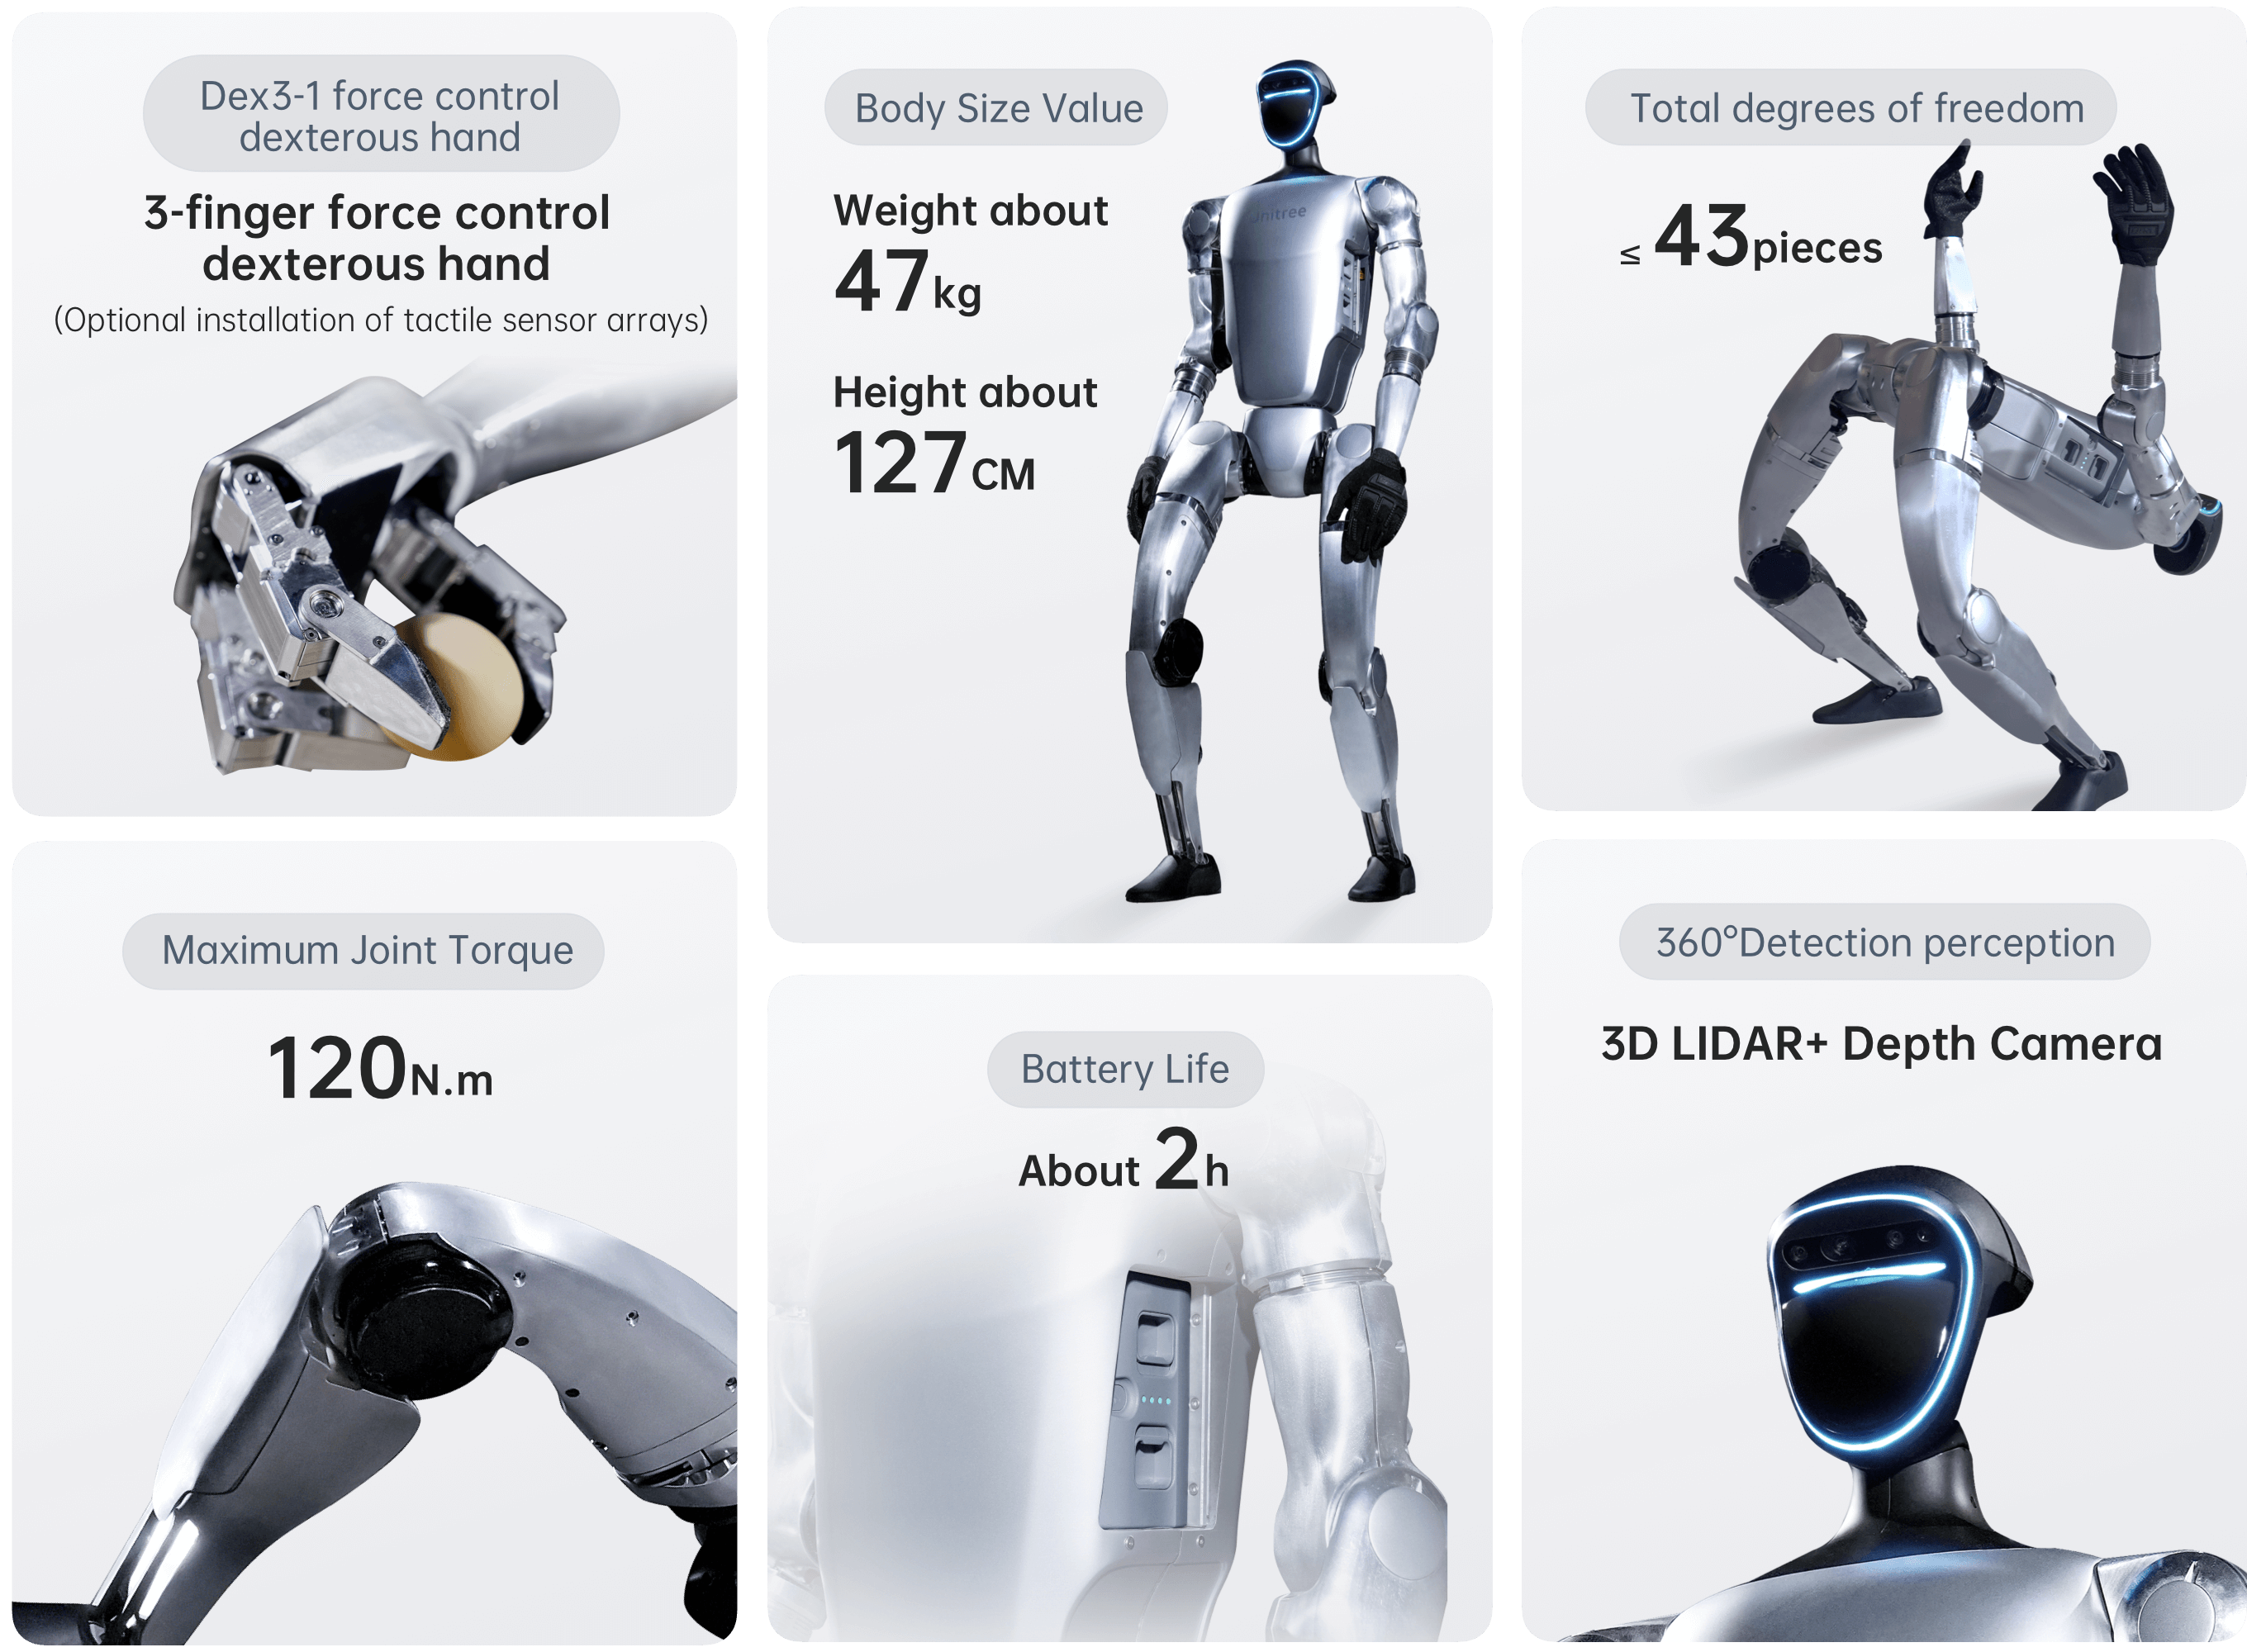
The basic version of the Unitree G1 primarily serves as an impressive demonstration and showcase model. It is ideal for presenting the robot’s dynamic movement, stability, and performance – without requiring any programming.
For those who want to dive deeper into robotics research, the EDU versions are the right choice:
Only these variants are fully programmable and provide an open development platform for both high-level and low-level control. This enables custom motion sequences, control algorithms, and advanced AI functionalities.
Unitree G1 – Model Overview
Comparison of all G1 variants (Basic, Pro, Edu series, Boxing, Comp) including the application focus and total degrees of freedom (DOF).
| Model |
Description |
DOF |
| G1 Basic – Entry-level |
Compact, robust, and ready to use out of the box. Ideal for first applications without programming. |
23 |
| G1 Pro – Entertainment |
Reinforced performance for tourism, events, and content production. 120 N·m knee, 3 kg arm load, 128-line LiDAR, unlocked motion routines (dance, kung-fu, rolling). No open-source development. |
29 |
| EDU-U1 – Programmable entry |
With NVIDIA Orin NX (100 TOPS) and a full development environment for AI and robotics. |
23 |
| EDU-U2 – Advanced research |
Increased mobility with 7-DOF arms and 3-DOF waist for complex applications. |
29 |
| EDU-U3 – Grasping (base) |
2× Dex3-1 force-controlled three-finger grippers (no tactile sensing). Based on U2. |
43 |
| EDU-U4 – Grasping (tactile) |
2× Dex3-1 three-finger grippers with tactile sensing (33 sensors per hand). Based on U2. |
43 |
| EDU-U5 – Fine manipulation |
2× Inspire 5-finger hands RH56DFQ-2 (R/L), without tactile sensing. Based on U2. |
41 |
| EDU-U6 – High-end |
2× Inspire 5-finger hands RH56DFTP-2 (R/L) with 17 tactile sensors per hand. Based on U2. |
41 |
| EDU-U7 – Revo 2 Basic |
2× BrainCo Revo 2 Basic 5-finger hands (no tactile sensing). Based on U2. |
41 |
| EDU-U8 – Revo 2 Touch |
2× BrainCo Revo 2 Touch 5-finger hands with tactile sensing (pressure, friction, direction, proximity). Based on U2. |
41 |
| EDU-U9 – Compact |
2× Dex3-1 three-finger grippers (no tactile sensing). Based on U1. |
37 |
| EDU-U10 – Compact + tactile |
2× Dex3-1 three-finger grippers with tactile sensing (33 sensors per hand). Based on U1. |
37 |
| EDU-U11 – Revo 2 Basic compact |
2× BrainCo Revo 2 Basic 5-finger hands (no tactile sensing). Based on U1. |
35 |
| EDU-U12 – Revo 2 Touch compact |
2× BrainCo Revo 2 Touch 5-finger hands with tactile sensing. Based on U1. |
35 |
| EDU-U13 – Tendon-rope |
2× tendon-rope dexterity hands (no tactile sensing), concealed internal wiring. Based on U2. |
33 |
| EDU-U14 – Tendon-rope compact |
2× in-house tendon-rope dexterity hands (no tactile sensing), concealed internal wiring. Based on U1. Longer lead time. |
27 |
| G1 Edu Boxing |
Combat variant with reinforced waist (IM6010-R32), armor, boxing gloves, and helmet. Suitable for UFB / ICRA WBCD events. Based on U2. No free warranty; instead a maintenance budget of USD 4,500 is provided. |
29 |
| G1-Comp |
RoboCup Soccer Humanoid League variant with an additional 2-DOF head, D455 depth camera, NVIDIA Jetson Orin, and 100 TOPS of computing power. |
25 |
DOF = total number of active articulated degrees of freedom, including hands/grippers. "Based on U1" = Edu Standard with 5-DOF arms and 1-DOF waist (23 DOF base frame); "Based on U2" = Edu Advanced with 7-DOF arms and 3-DOF waist (29 DOF base frame).
Specifications
| Specification |
G1 Base |
G1 Standard Version |
G1 Advanced Version |
| Dimensions (standing) |
1270 × 450 × 200 mm |
1270 × 450 × 200 mm |
1270 × 450 × 200 mm |
| Dimensions (folded) |
690 × 450 × 300 mm |
690 × 450 × 300 mm |
690 × 450 × 300 mm |
| Weight |
approx. 35 kg |
approx. 35 kg+ |
approx. 35 kg+ |
| Degrees of Freedom |
23 |
23–43 |
23–43 |
| Programmability |
No |
Yes |
Yes |
| Operating Time |
approx. 2 h |
approx. 2 h |
approx. 2 h |
Scope of Delivery
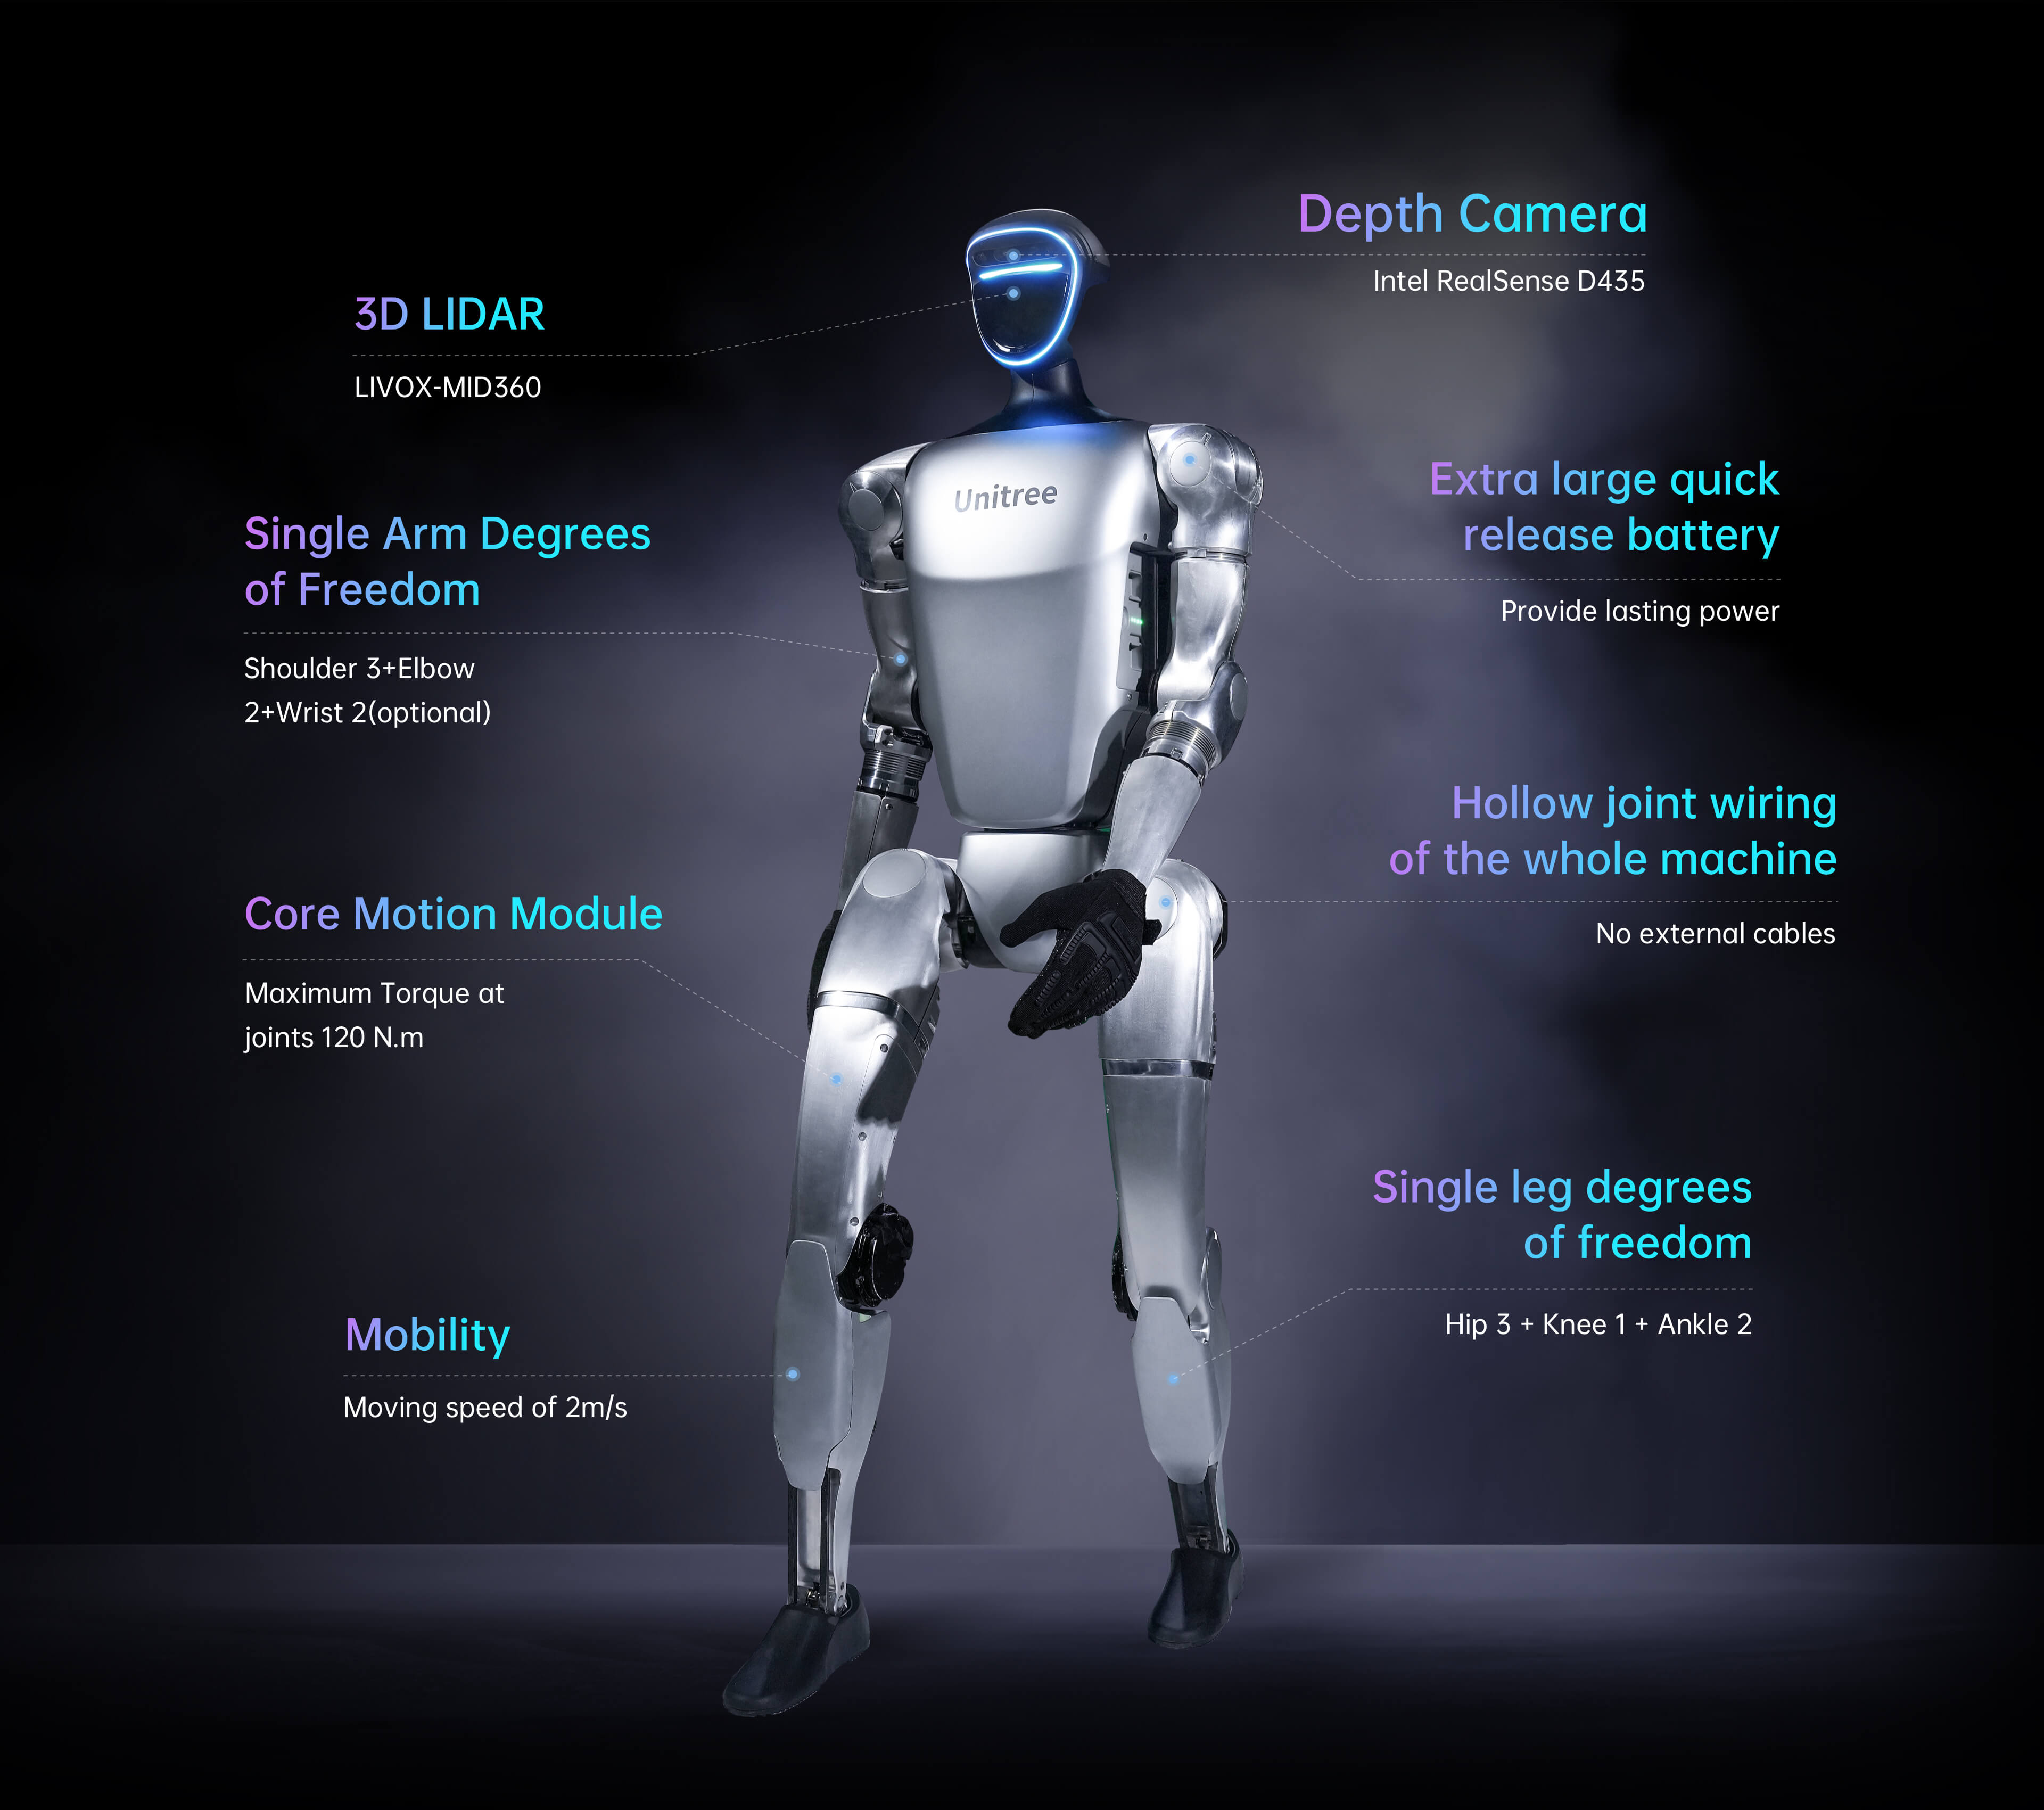
- Unitree G1 (depending on version)
- Controller
- 9,000 mAh battery